 |
ros2_control - humble
|
Loading...
Searching...
No Matches
|
ros2_control - humble
|
#include <mock_pendulum_hardware.hpp>
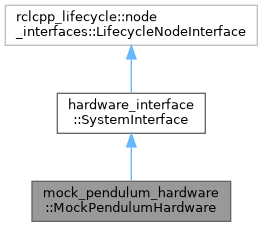
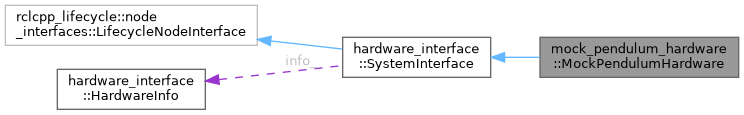
Public Member Functions | |
| CallbackReturn | on_init (const hardware_interface::HardwareComponentInterfaceParams ¶ms) override |
| std::vector< hardware_interface::StateInterface::ConstSharedPtr > | on_export_state_interfaces () override |
| std::vector< hardware_interface::CommandInterface::SharedPtr > | on_export_command_interfaces () override |
| CallbackReturn | on_activate (const rclcpp_lifecycle::State &previous_state) override |
| CallbackReturn | on_deactivate (const rclcpp_lifecycle::State &previous_state) override |
| hardware_interface::return_type | read (const rclcpp::Time &time, const rclcpp::Duration &period) override |
| Read the current state values from the actuator. | |
| hardware_interface::return_type | write (const rclcpp::Time &time, const rclcpp::Duration &period) override |
| Write the current command values to the actuator. | |
 Public Member Functions inherited from hardware_interface::SystemInterface | |
| SystemInterface (const SystemInterface &other)=delete | |
| SystemInterface copy constructor is actively deleted. | |
| SystemInterface (SystemInterface &&other)=default | |
| virtual CallbackReturn | on_init (const HardwareInfo &hardware_info) |
| Initialization of the hardware interface from data parsed from the robot's URDF. | |
| virtual std::vector< StateInterface > | export_state_interfaces ()=0 |
| Exports all state interfaces for this hardware interface. | |
| virtual std::vector< CommandInterface > | export_command_interfaces ()=0 |
| Exports all command interfaces for this hardware interface. | |
| virtual return_type | prepare_command_mode_switch (const std::vector< std::string > &, const std::vector< std::string > &) |
| Prepare for a new command interface switch. | |
| virtual return_type | perform_command_mode_switch (const std::vector< std::string > &, const std::vector< std::string > &) |
| virtual std::string | get_name () const |
| Get name of the actuator hardware. | |
| const rclcpp_lifecycle::State & | get_state () const |
| Get life-cycle state of the actuator hardware. | |
| void | set_state (const rclcpp_lifecycle::State &new_state) |
| Set life-cycle state of the actuator hardware. | |
Additional Inherited Members | |
| Protected Attributes inherited from hardware_interface::SystemInterface | |
| HardwareInfo | info_ |
| rclcpp_lifecycle::State | lifecycle_state_ |
Mock hardware for a rotary (Furuta) inverted pendulum.
Angle conventions (chosen to match the controller, NOT the URDF joint zero): q1 (motor_joint) : arm angle, 0 = wherever the operator centred the arm, mechanically limited to +-135 deg by the lid bosses. q2 (pendulum_joint) : 0 = UPRIGHT, +-pi = hanging. Always reported wrapped into [-pi, pi].
The URDF's arm_to_pendulum zero is the hanging pose; this interface offsets that by pi so the controller sees the usual "error = q2" upright convention.
|
overridevirtual |
Read the current state values from the actuator.
The data readings from the physical hardware has to be updated and reflected accordingly in the exported state interfaces. That is, the data pointed by the interfaces shall be updated.
| [in] | time | The time at the start of this control loop iteration |
| [in] | period | The measured time taken by the last control loop iteration |
Implements hardware_interface::SystemInterface.
|
overridevirtual |
Write the current command values to the actuator.
The physical hardware shall be updated with the latest value from the exported command interfaces.
| [in] | time | The time at the start of this control loop iteration |
| [in] | period | The measured time taken by the last control loop iteration |
Implements hardware_interface::SystemInterface.
 1.9.8