 |
ros2_control - kilted
|
Loading...
Searching...
No Matches
|
ros2_control - kilted
|
Simple plugin that publishes a heartbeat message every second. More...
#include <heartbeat_publisher_plugin.hpp>
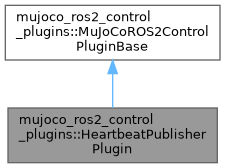
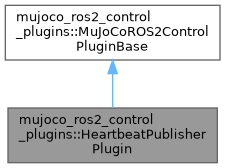
Public Member Functions | |
| bool | init (rclcpp::Node::SharedPtr node, const mjModel *model, mjData *data) override |
| Initialize the plugin. | |
| void | update_write (const mjModel *model, mjData *data) override |
| Update the plugin (called every simulation step) | |
| void | cleanup () override |
| Cleanup the plugin. | |
 Public Member Functions inherited from mujoco_ros2_control_plugins::MuJoCoROS2ControlPluginBase | |
| virtual void | update_read (const mjModel *, mjData *) |
Called once per read() cycle, on the control thread, before the state is handed to ros2_control. Default does nothing. | |
| virtual void | update (const mjModel *, mjData *) |
Same as update_write(). Default does nothing. | |
| virtual void | pre_step (mjData *) |
| Called immediately before every simulation step on the physics thread. Default does nothing. | |
| virtual void | on_reset (mjData *) |
| Called after a world reset (ResetWorld service or UI reset). Default does nothing. | |
Simple plugin that publishes a heartbeat message every second.
|
overridevirtual |
Cleanup the plugin.
Implements mujoco_ros2_control_plugins::MuJoCoROS2ControlPluginBase.
|
overridevirtual |
Initialize the plugin.
Implements mujoco_ros2_control_plugins::MuJoCoROS2ControlPluginBase.
|
overridevirtual |
Update the plugin (called every simulation step)
Reimplemented from mujoco_ros2_control_plugins::MuJoCoROS2ControlPluginBase.
 1.9.8