 |
ros2_control - rolling
|
Loading...
Searching...
No Matches
|
ros2_control - rolling
|
#include <mock_pendulum_hardware.hpp>

Public Member Functions | |
| CallbackReturn | on_init (const hardware_interface::HardwareComponentInterfaceParams ¶ms) override |
| Initialization of the hardware interface from data parsed from the robot's URDF. | |
| std::vector< hardware_interface::StateInterface > | export_state_interfaces () override |
| std::vector< hardware_interface::CommandInterface > | export_command_interfaces () override |
| CallbackReturn | on_activate (const rclcpp_lifecycle::State &previous_state) override |
| CallbackReturn | on_deactivate (const rclcpp_lifecycle::State &previous_state) override |
| hardware_interface::return_type | read (const rclcpp::Time &time, const rclcpp::Duration &period) override |
| Read the current state values from the hardware. | |
| hardware_interface::return_type | write (const rclcpp::Time &time, const rclcpp::Duration &period) override |
| Write the current command values to the hardware. | |
 Public Member Functions inherited from hardware_interface::HardwareComponentInterface | |
| HardwareComponentInterface (const HardwareComponentInterface &other)=delete | |
| HardwareComponentInterface copy constructor is actively deleted. | |
| HardwareComponentInterface (HardwareComponentInterface &&other)=delete | |
| CallbackReturn | init (const hardware_interface::HardwareComponentParams ¶ms) |
| virtual CallbackReturn | init_hardware_status_message (control_msgs::msg::HardwareStatus &msg_template) |
| User-overridable method to configure the structure of the HardwareStatus message. | |
| virtual return_type | update_hardware_status_message (control_msgs::msg::HardwareStatus &msg) |
| User-overridable method to fill the hardware status message with real-time data. | |
| virtual rclcpp::NodeOptions | define_custom_node_options () const |
| Define custom node options for the hardware component interface. | |
| virtual std::vector< hardware_interface::InterfaceDescription > | export_unlisted_state_interface_descriptions () |
| virtual std::vector< StateInterface::ConstSharedPtr > | on_export_state_interfaces () |
| virtual std::vector< hardware_interface::InterfaceDescription > | export_unlisted_command_interface_descriptions () |
| virtual std::vector< CommandInterface::SharedPtr > | on_export_command_interfaces () |
| virtual return_type | prepare_command_mode_switch (const std::vector< std::string > &start_interfaces, const std::vector< std::string > &stop_interfaces) |
| Prepare for a new command interface switch. | |
| virtual return_type | perform_command_mode_switch (const std::vector< std::string > &start_interfaces, const std::vector< std::string > &stop_interfaces) |
| HardwareComponentCycleStatus | trigger_read (const rclcpp::Time &time, const rclcpp::Duration &period) |
| Triggers the read method synchronously or asynchronously depending on the HardwareInfo. | |
| HardwareComponentCycleStatus | trigger_write (const rclcpp::Time &time, const rclcpp::Duration &period) |
| Triggers the write method synchronously or asynchronously depending on the HardwareInfo. | |
| const std::string & | get_name () const |
| Get name of the hardware. | |
| const std::string & | get_group_name () const |
| Get name of the hardware group to which it belongs to. | |
| const rclcpp_lifecycle::State & | get_lifecycle_state () const |
| Get life-cycle state of the hardware. | |
| void | set_lifecycle_state (const rclcpp_lifecycle::State &new_state) |
| Set life-cycle state of the hardware. | |
| uint8_t | get_lifecycle_id () const |
| Get the lifecycle id of the hardware component interface. | |
| virtual bool | has_state (const std::string &interface_name) const |
| Does the state interface exist? | |
| virtual const StateInterface::SharedPtr & | get_state_interface_handle (const std::string &interface_name) const |
| Get the state interface handle. | |
| template<typename T > | |
| bool | set_state (const StateInterface::SharedPtr &interface_handle, const T &value, bool wait_until_set) |
| Set the value of a state interface. | |
| template<typename T > | |
| void | set_state (const std::string &interface_name, const T &value) |
| Set the value of a state interface. | |
| template<typename T > | |
| bool | get_state (const StateInterface::SharedPtr &interface_handle, T &state, bool wait_until_get) const |
| template<typename T = double> | |
| T | get_state (const std::string &interface_name) const |
| Get the value from a state interface. | |
| virtual bool | has_command (const std::string &interface_name) const |
| Does the command interface exist? | |
| virtual const CommandInterface::SharedPtr & | get_command_interface_handle (const std::string &interface_name) const |
| Get the command interface handle. | |
| template<typename T > | |
| bool | set_command (const CommandInterface::SharedPtr &interface_handle, const T &value, bool wait_until_set) |
| Set the value of a command interface. | |
| template<typename T > | |
| void | set_command (const std::string &interface_name, const T &value) |
| Set the value of a command interface. | |
| template<typename T > | |
| bool | get_command (const CommandInterface::SharedPtr &interface_handle, T &command, bool wait_until_get) const |
| template<typename T = double> | |
| T | get_command (const std::string &interface_name) const |
| Get the value from a command interface. | |
| virtual rclcpp::Logger | get_logger () const |
| Get the logger of the HardwareComponentInterface. | |
| virtual rclcpp::Clock::SharedPtr | get_clock () const |
| Get the clock. | |
| virtual rclcpp::Node::SharedPtr | get_node () const |
| Get the default node of the HardwareComponentInterface. | |
| const HardwareInfo & | get_hardware_info () const |
| Get the hardware info of the HardwareComponentInterface. | |
| void | pause_async_operations () |
| Pause any asynchronous operations. | |
| void | stop_async_handler () |
| Stop and release the async handler thread. | |
| void | prepare_for_activation () |
| Prepare for the activation of the hardware. | |
| void | enable_introspection (bool enable) |
| Enable or disable introspection of the hardware. | |
Additional Inherited Members | |
| Protected Attributes inherited from hardware_interface::HardwareComponentInterface | |
| HardwareInfo | info_ |
| std::unordered_map< std::string, InterfaceDescription > | joint_state_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | joint_command_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | sensor_state_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | gpio_state_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | gpio_command_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | unlisted_state_interfaces_ |
| std::unordered_map< std::string, InterfaceDescription > | unlisted_command_interfaces_ |
| rclcpp_lifecycle::State | lifecycle_state_ |
| std::unique_ptr< realtime_tools::AsyncFunctionHandler< return_type > > | async_handler_ |
| std::vector< StateInterface::SharedPtr > | joint_states_ |
| std::vector< CommandInterface::SharedPtr > | joint_commands_ |
| std::vector< StateInterface::SharedPtr > | sensor_states_ |
| std::vector< StateInterface::SharedPtr > | gpio_states_ |
| std::vector< CommandInterface::SharedPtr > | gpio_commands_ |
| std::vector< StateInterface::SharedPtr > | unlisted_states_ |
| std::vector< CommandInterface::SharedPtr > | unlisted_commands_ |
| pal_statistics::RegistrationsRAII | stats_registrations_ |
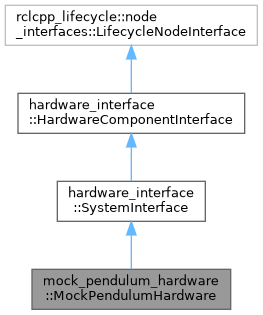
In-process mock hardware that simulates Furuta pendulum dynamics.
State interfaces: motor_joint/position (rad) motor_joint/velocity (rad/s) pendulum_joint/position (rad) pendulum_joint/velocity (rad/s)
Command interfaces: motor_joint/acceleration (rad/s^2)
The commanded acceleration is applied directly to the motor joint. Coupled 2-DOF Lagrangian dynamics determine the pendulum response.
|
overridevirtual |
Initialization of the hardware interface from data parsed from the robot's URDF.
| [in] | params | A struct of type hardware_interface::HardwareComponentInterfaceParams containing all necessary parameters for initializing this specific hardware component, specifically its HardwareInfo, and a weak_ptr to the executor. |
cancel() or use blocking callbacks such as spin(). Reimplemented from hardware_interface::HardwareComponentInterface.
|
overridevirtual |
Read the current state values from the hardware.
The data readings from the physical hardware has to be updated and reflected accordingly in the exported state interfaces. That is, the data pointed by the interfaces shall be updated.
| [in] | time | The time at the start of this control loop iteration |
| [in] | period | The measured time taken by the last control loop iteration |
Implements hardware_interface::HardwareComponentInterface.
|
overridevirtual |
Write the current command values to the hardware.
The physical hardware shall be updated with the latest value from the exported command interfaces.
| [in] | time | The time at the start of this control loop iteration |
| [in] | period | The measured time taken by the last control loop iteration |
Implements hardware_interface::SystemInterface.
 1.9.8