 |
ros2_control - rolling
|
Loading...
Searching...
No Matches
|
ros2_control - rolling
|
Public Attributes | |
| std::shared_ptr< rclcpp_lifecycle::LifecycleNode > | node_ |
| std::unique_ptr< realtime_tools::AsyncFunctionHandler< return_type > > | async_handler_ |
| bool | is_async_ = false |
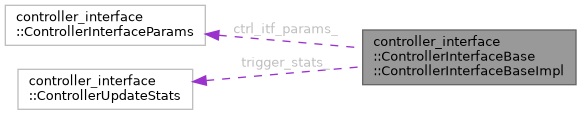
| controller_interface::ControllerInterfaceParams | ctrl_itf_params_ |
| std::atomic_bool | skip_async_triggers_ = false |
| ControllerUpdateStats | trigger_stats_ |
| std::atomic< uint8_t > | lifecycle_id_ = lifecycle_msgs::msg::State::PRIMARY_STATE_UNKNOWN |
 1.15.0