 |
ros2_control - rolling
|
Loading...
Searching...
No Matches
|
ros2_control - rolling
|
#include <data.hpp>
Public Attributes | |
| std::string | name |
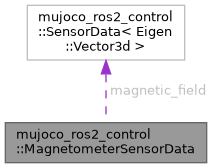
| SensorData< Eigen::Vector3d > | magnetic_field |
| double | magnetic_field_noise_stddev = 0.0 |
| NoiseState | noise |
| magnetic_field_noise_stddev | Standard deviation of zero-mean Gaussian noise added to magnetic_field on read; taken from the underlying MJCF <magnetometer> sensor's noise attribute (0 by default). |
| noise | Shape (ros2_control noise_distribution parameter, defaults to Gaussian) and RNG, seeded from std::random_device (noise is non-deterministic across runs). |
 1.9.8